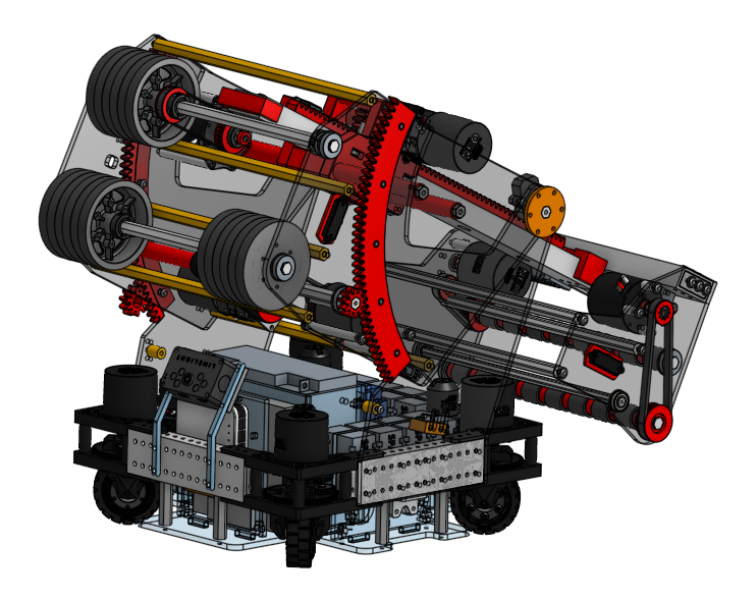
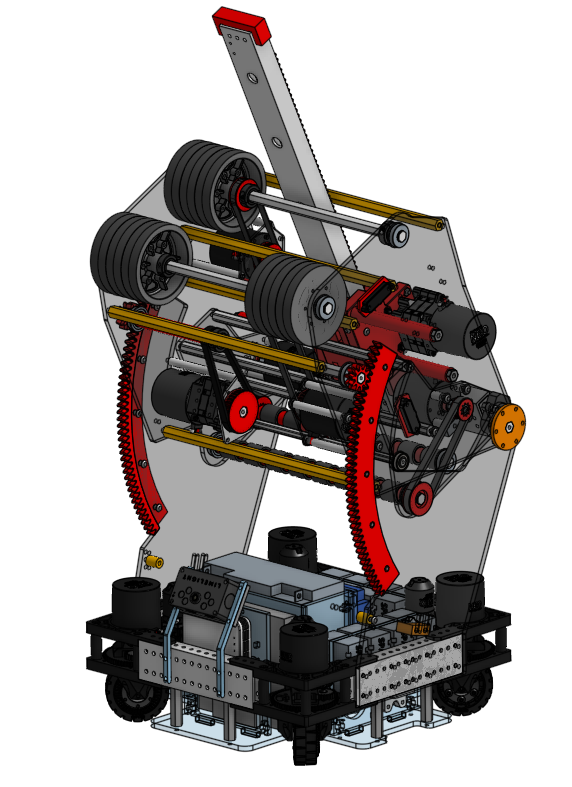
A personal robot design targeting one-quarter the volume of a traditional robot for the same 2024 FRC game.
Deployed configuration · CAD design
Stowed configuration · CAD design
1 / 2 · Deployed
The challenge
Design a competitive robot capable of high-level play with the smallest possible footprint. The battery alone is 7 inches wide and 6.5 inches tall. To keep costs low, I worked with components already on hand, including motors and motor controllers with much larger footprints than newer alternatives I could have purchased.
The approach
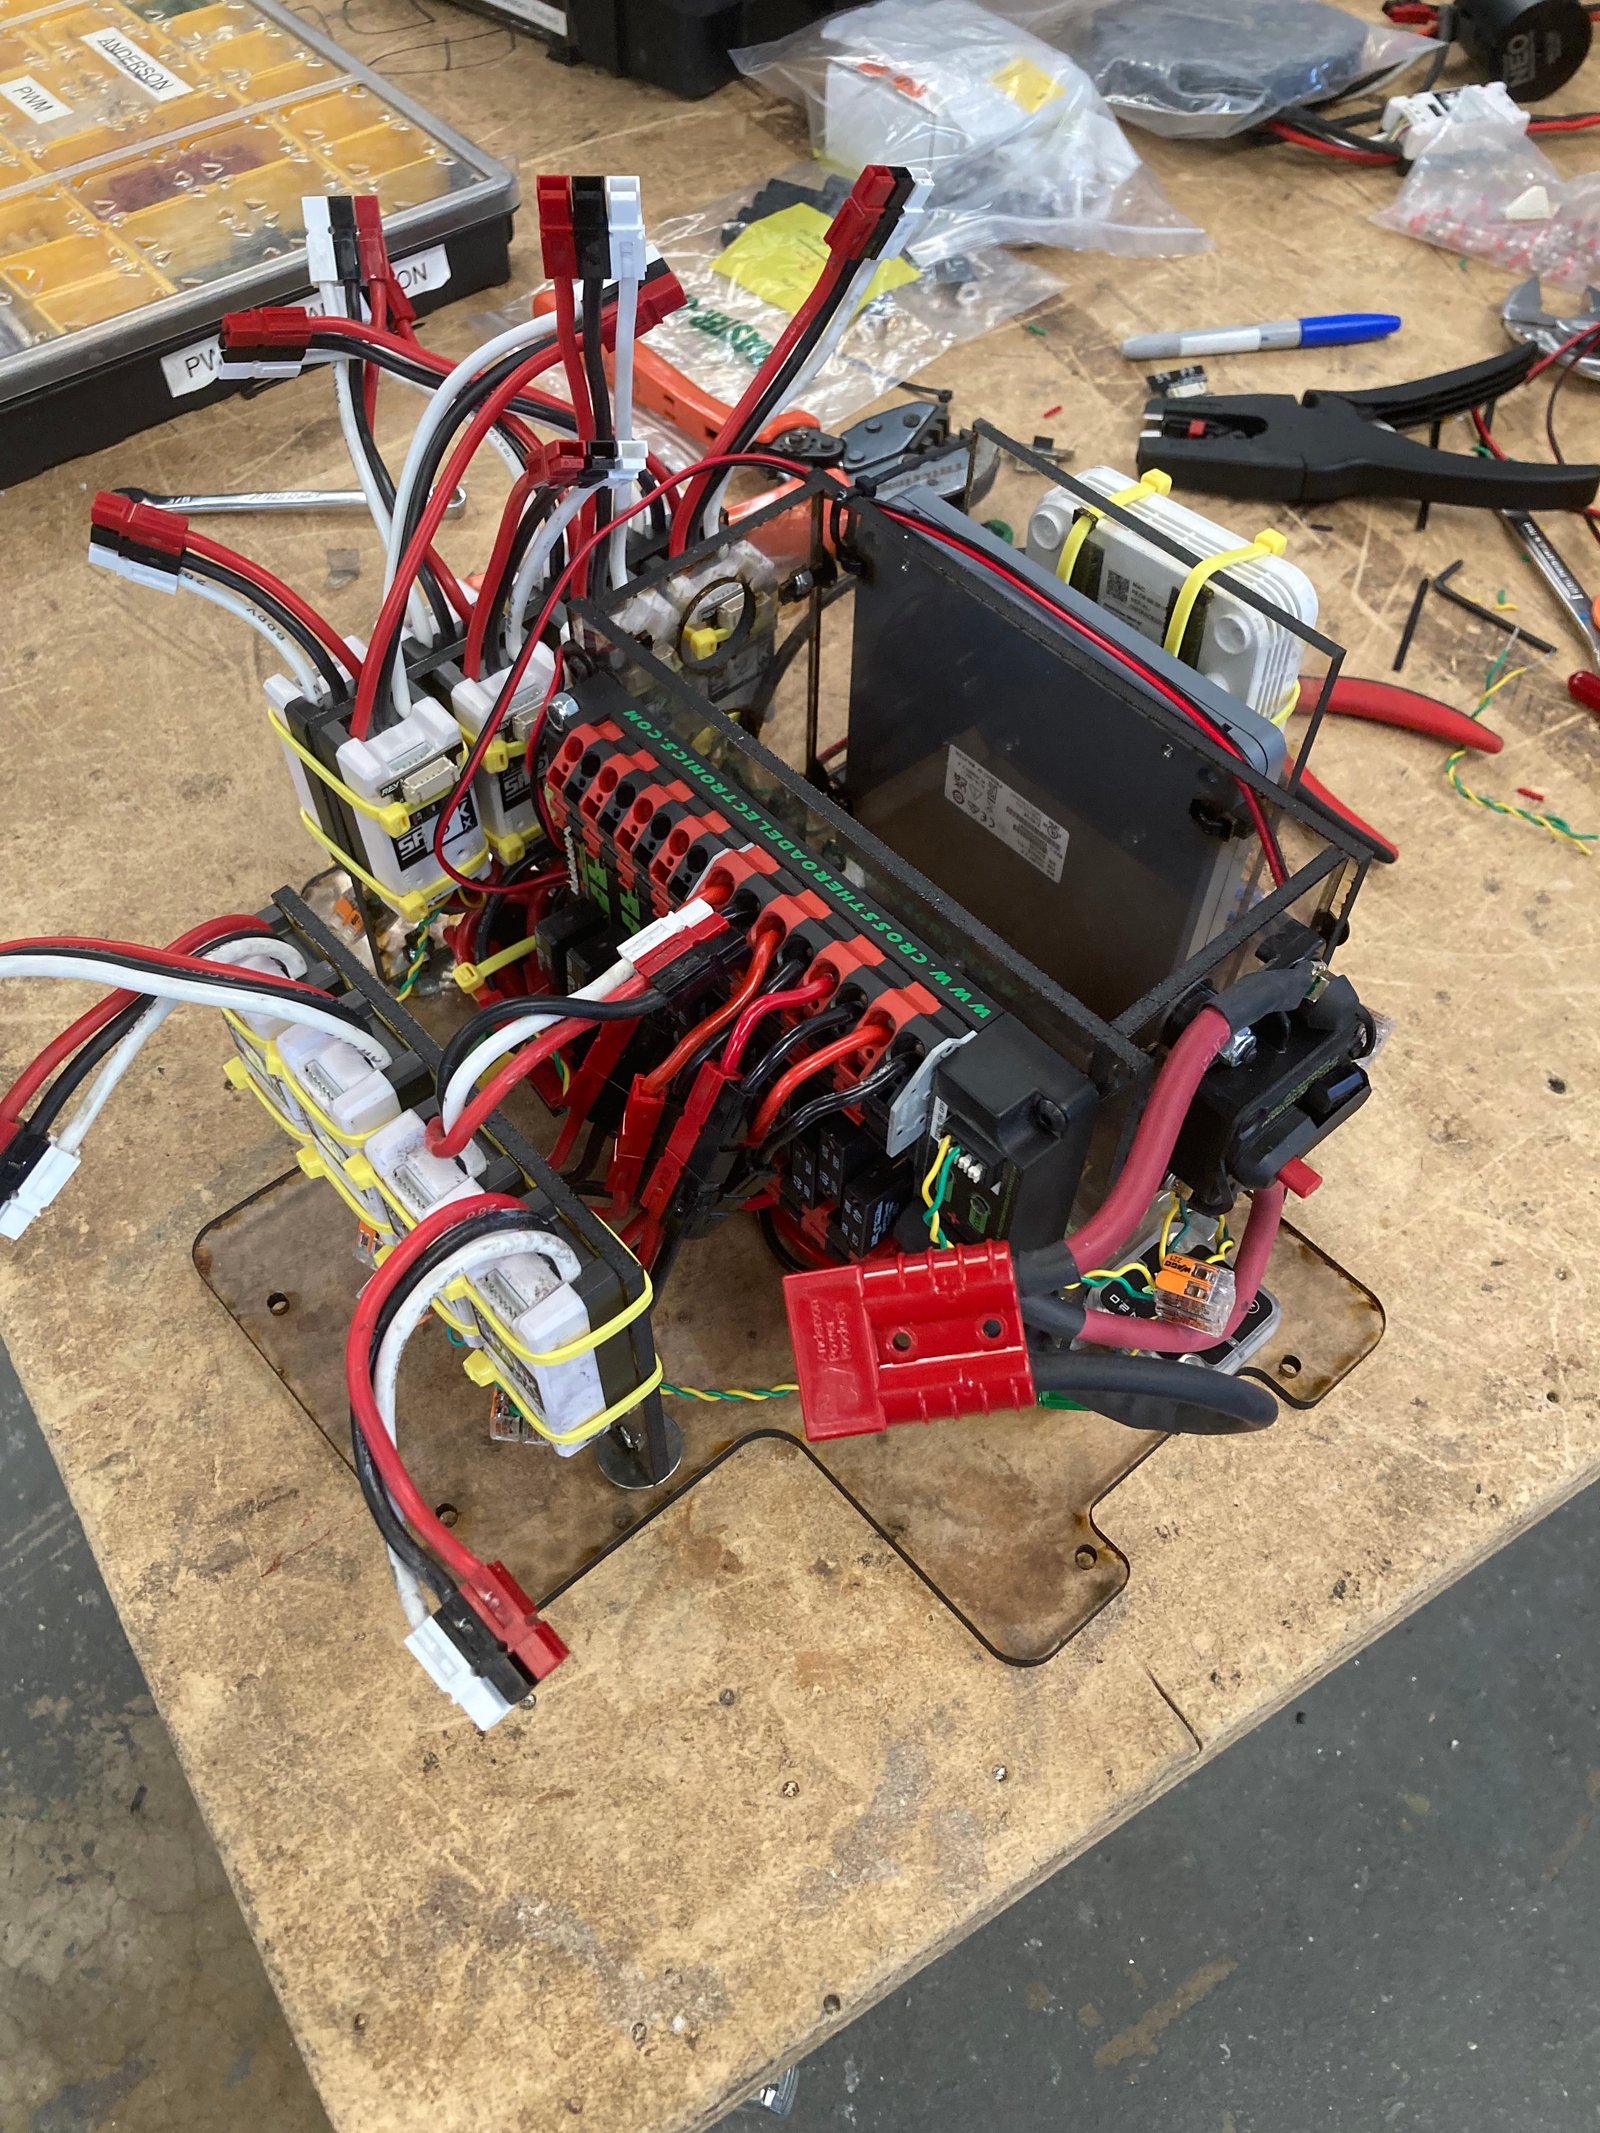
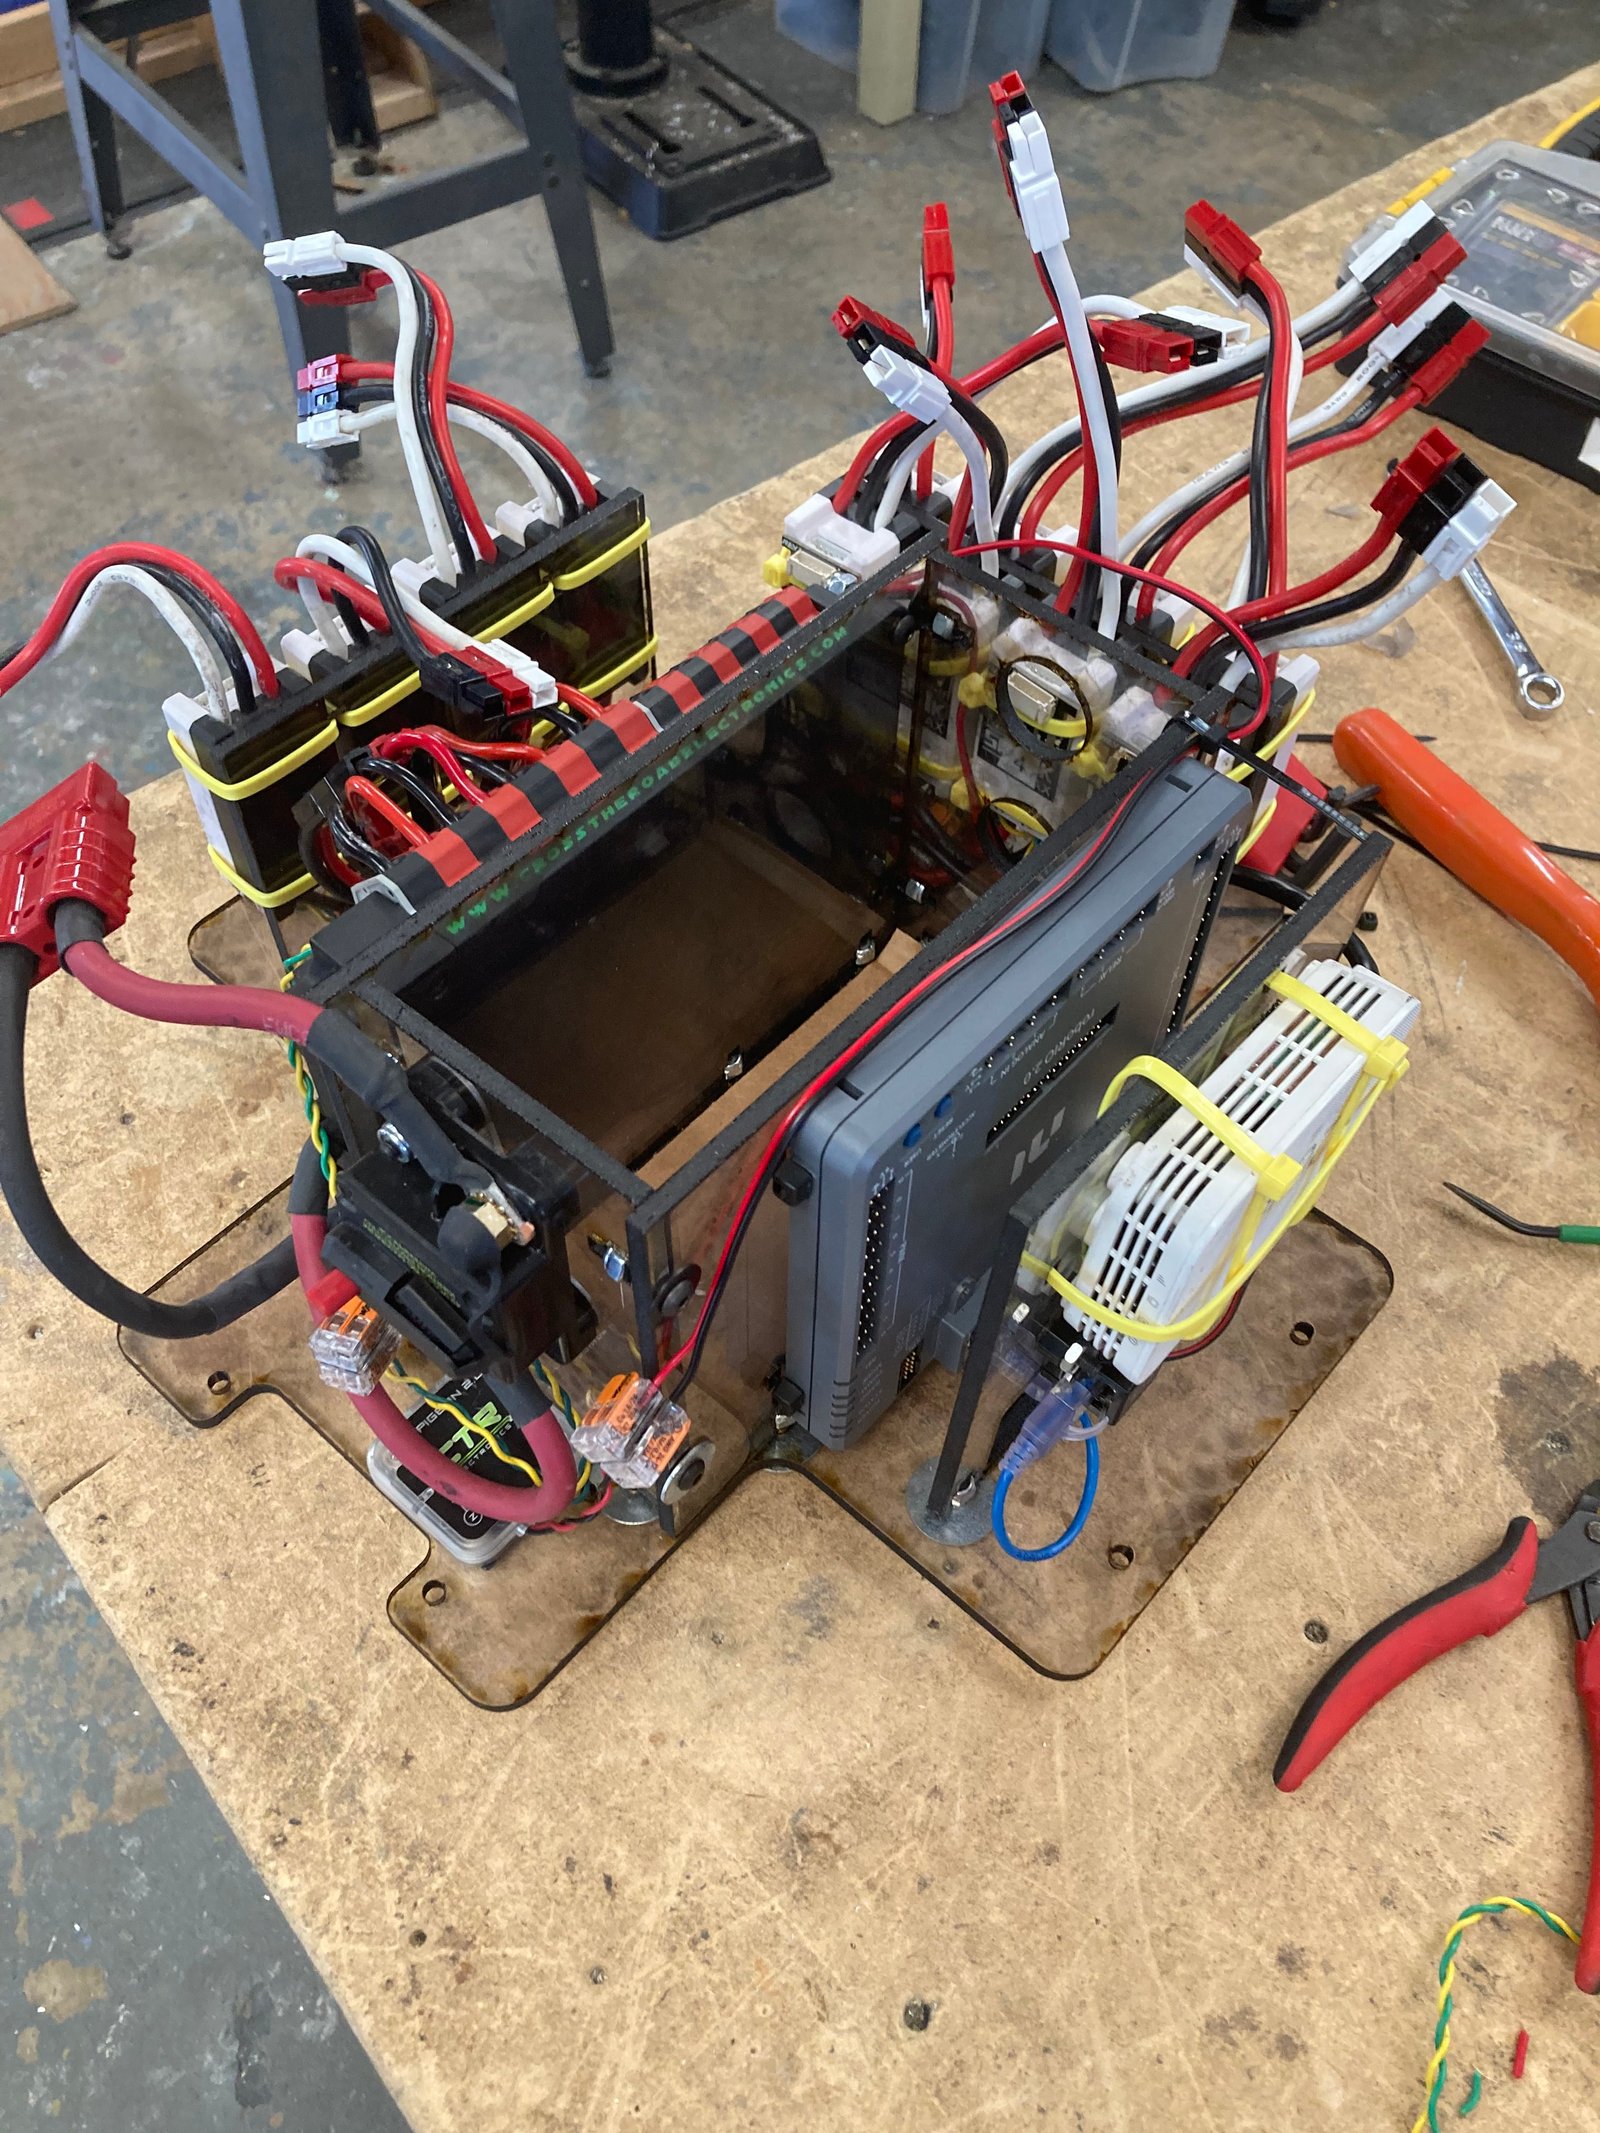
I started by finding the smallest footprint that could comfortably house all the electronics, then designed the mechanisms around it. Stacking the electronics vertically was an unconventional approach that I developed for this project. I designed vertical walls that slot and bolt into the floor and each other to create a rigid structure. Coincidentally, the robot ended up 14 inches wide, the same width as the game piece.
My contribution
I handled all of the ideation, design, prototyping, assembly, and wiring. A friend handled the software, and I contributed to manufacturing.
The outcome
A fully working drive base, with the electronics for the entire robot assembled, along with the intake. I completed the shooter CAD, but ultimately ran out of time before I could finish building the full robot.
Engineering decisions
Problems & solutions.
Vertical electronics layout
Packaging the electronics
Problem
The electronics took up too much space when mounted flat inside the compact robot.
Solution
I arranged the electronics vertically to make better use of the available space.
Result
The vertical layout was incorporated into the assembled and wired drive base.
Battery placement in the drive base
Managing stability
Problem
A high center of gravity created a tipping concern.
Solution
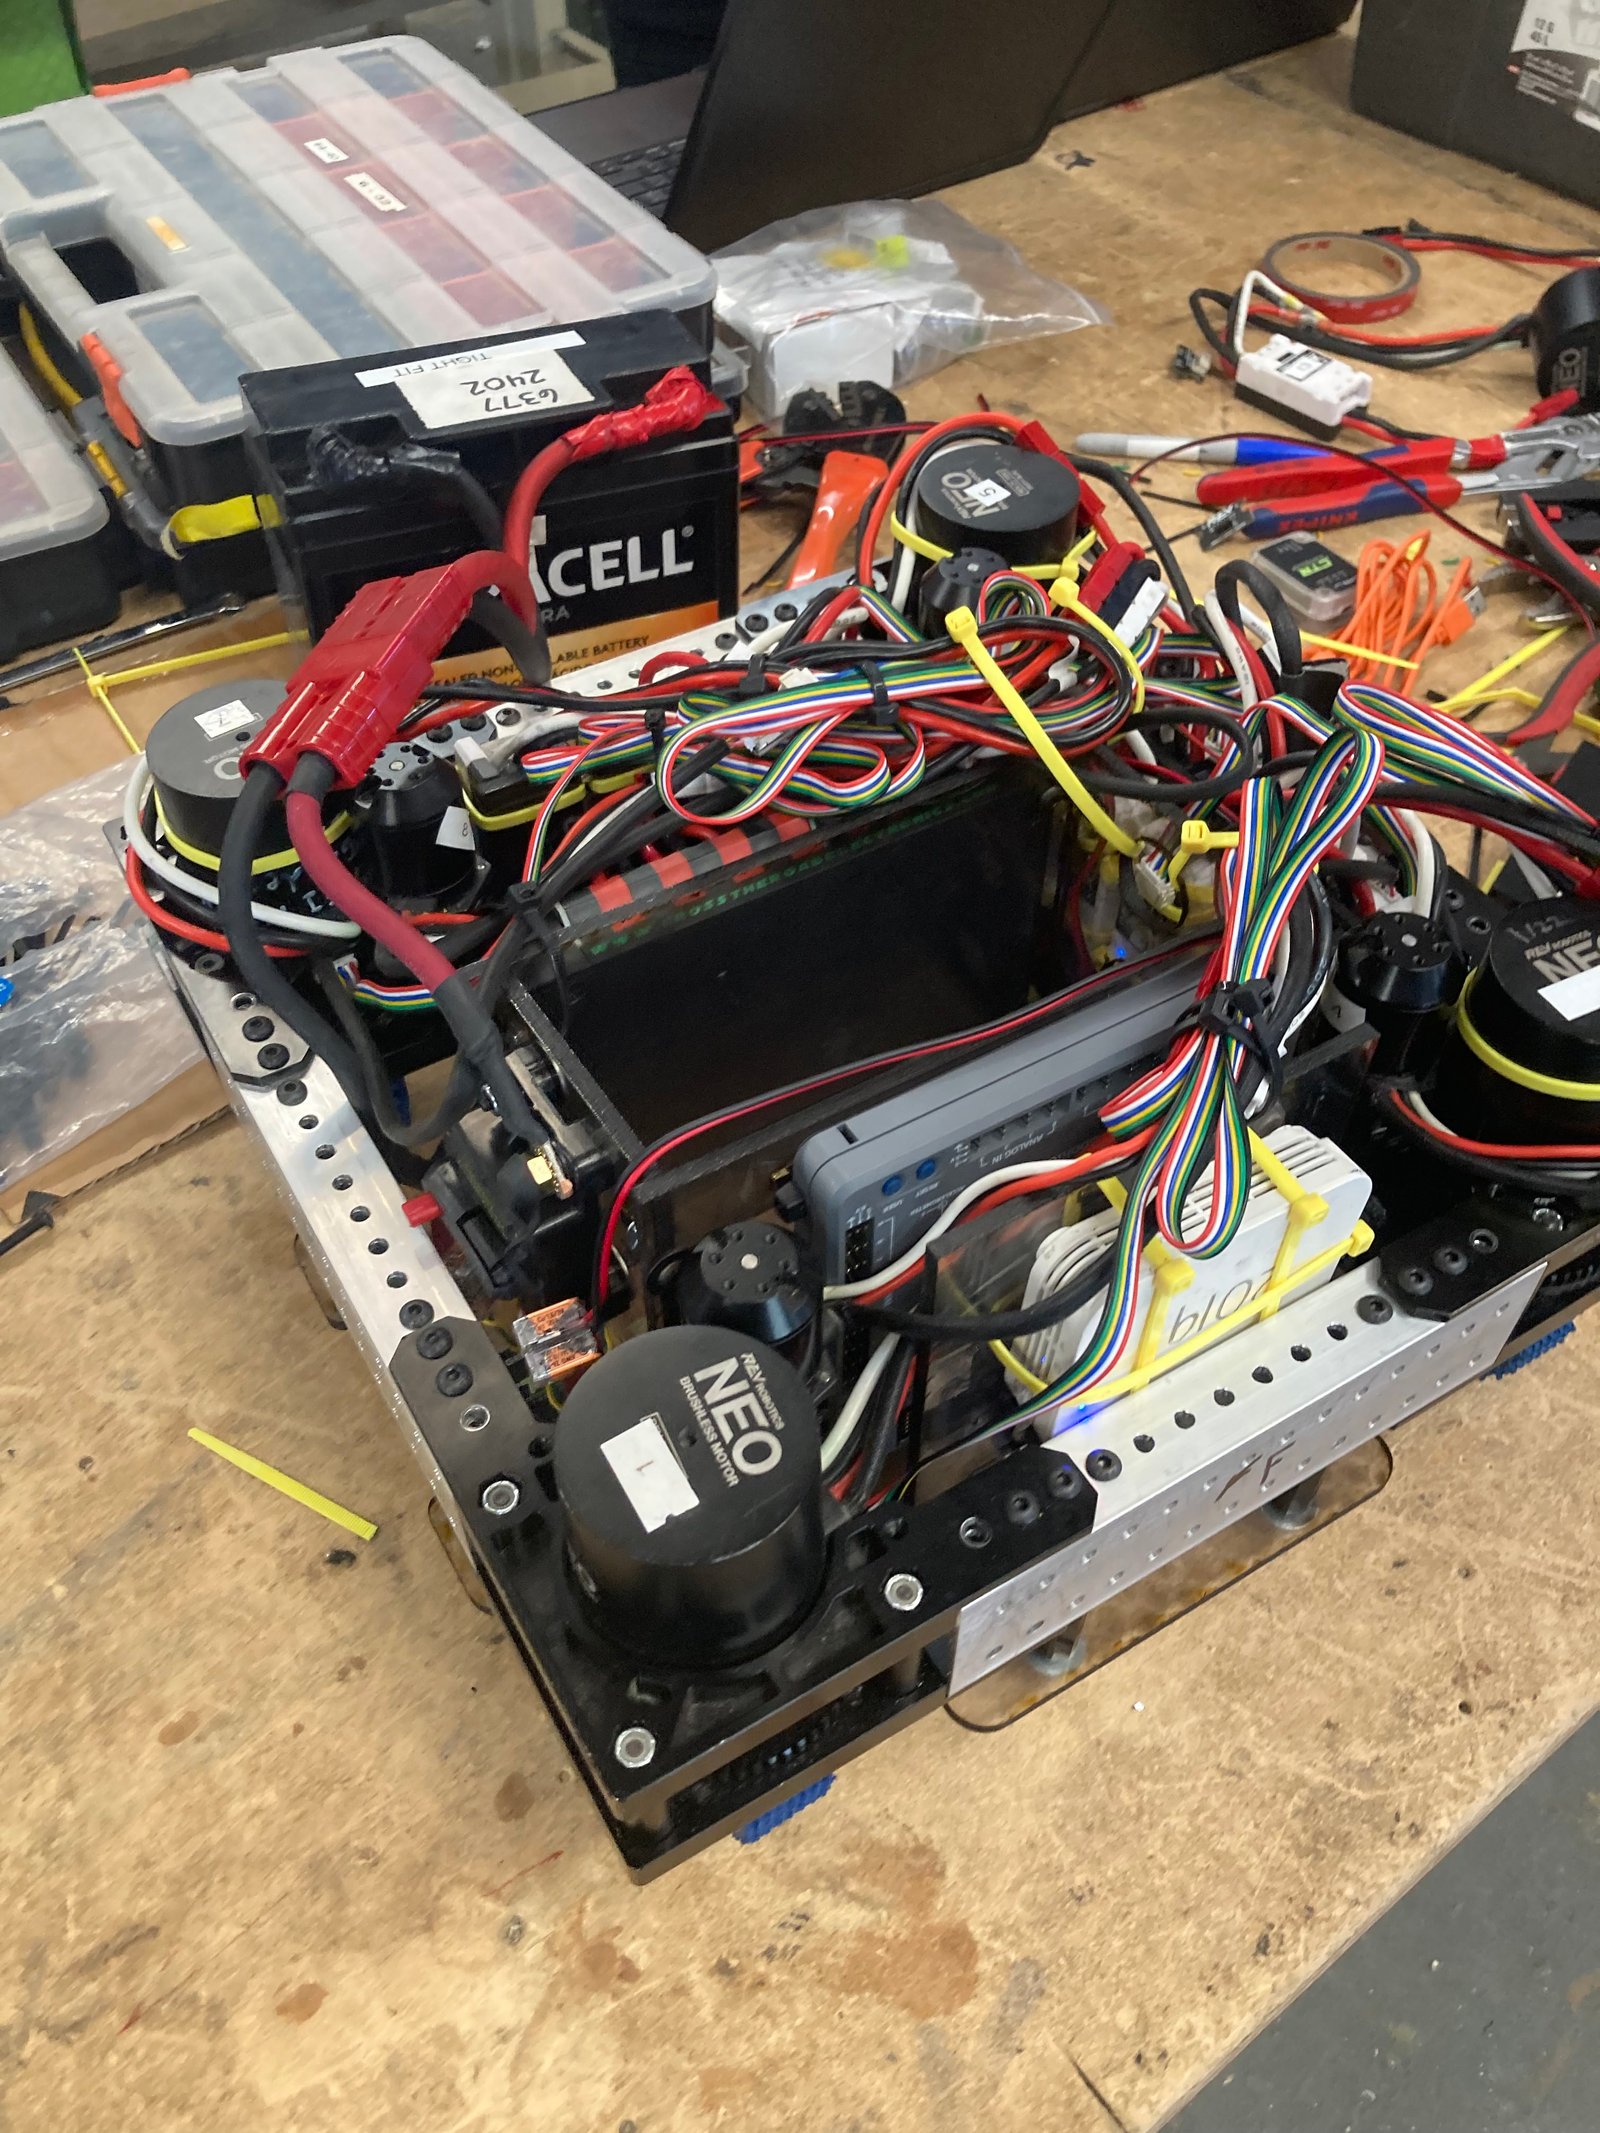
I used the heavy battery as ballast, positioning it to help address stability.
Result
The battery fits into the gap in the middle of the frame, visible in the photo, placing its weight low in the drive base to act as ballast. Driving footage is included below.
From CAD to hardware
Build photos.
Assembled drive baseElectronics packagingInternal wiring and layout