An autonomous ground vehicle project built by a rookie team of three, with a tight budget and no faculty or mentor assistance.
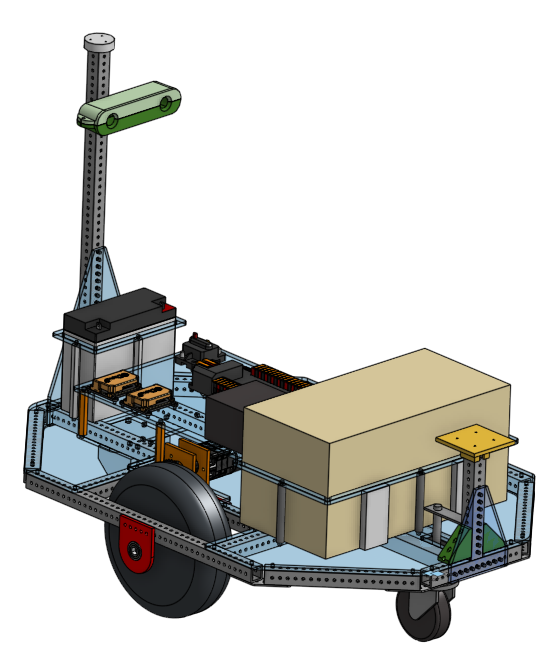
Full vehicle assembly · CAD design
The challenge
Design a fully autonomous ground vehicle capable of traversing inclines, making sharp turns, and avoiding obstacles. We were a rookie team with no prior experience or established resources, no faculty or mentor help, and a tight budget.
The approach
We researched previous competition winners and used their successful designs to guide our own decisions. To keep the build as affordable as possible, we used materials and components already on hand wherever we could.
My contribution
I led a team of three, including myself. I established the overall timeline, set smaller deadlines, and assigned work to keep us on track. I fully designed the drive system, helped with the other subsystems, and assisted with chassis assembly.
The outcome
We completed the CAD design ahead of our own deadline. The robot went on to compete in the 2026 Intelligent Ground Vehicle Competition.
Engineering decisions
Problems & solutions.
Chassis footprint
Reducing the turning footprint
Problem
Robots frequently clipped obstacles with their rear corners during turns, where sensor coverage was weakest.
Solution
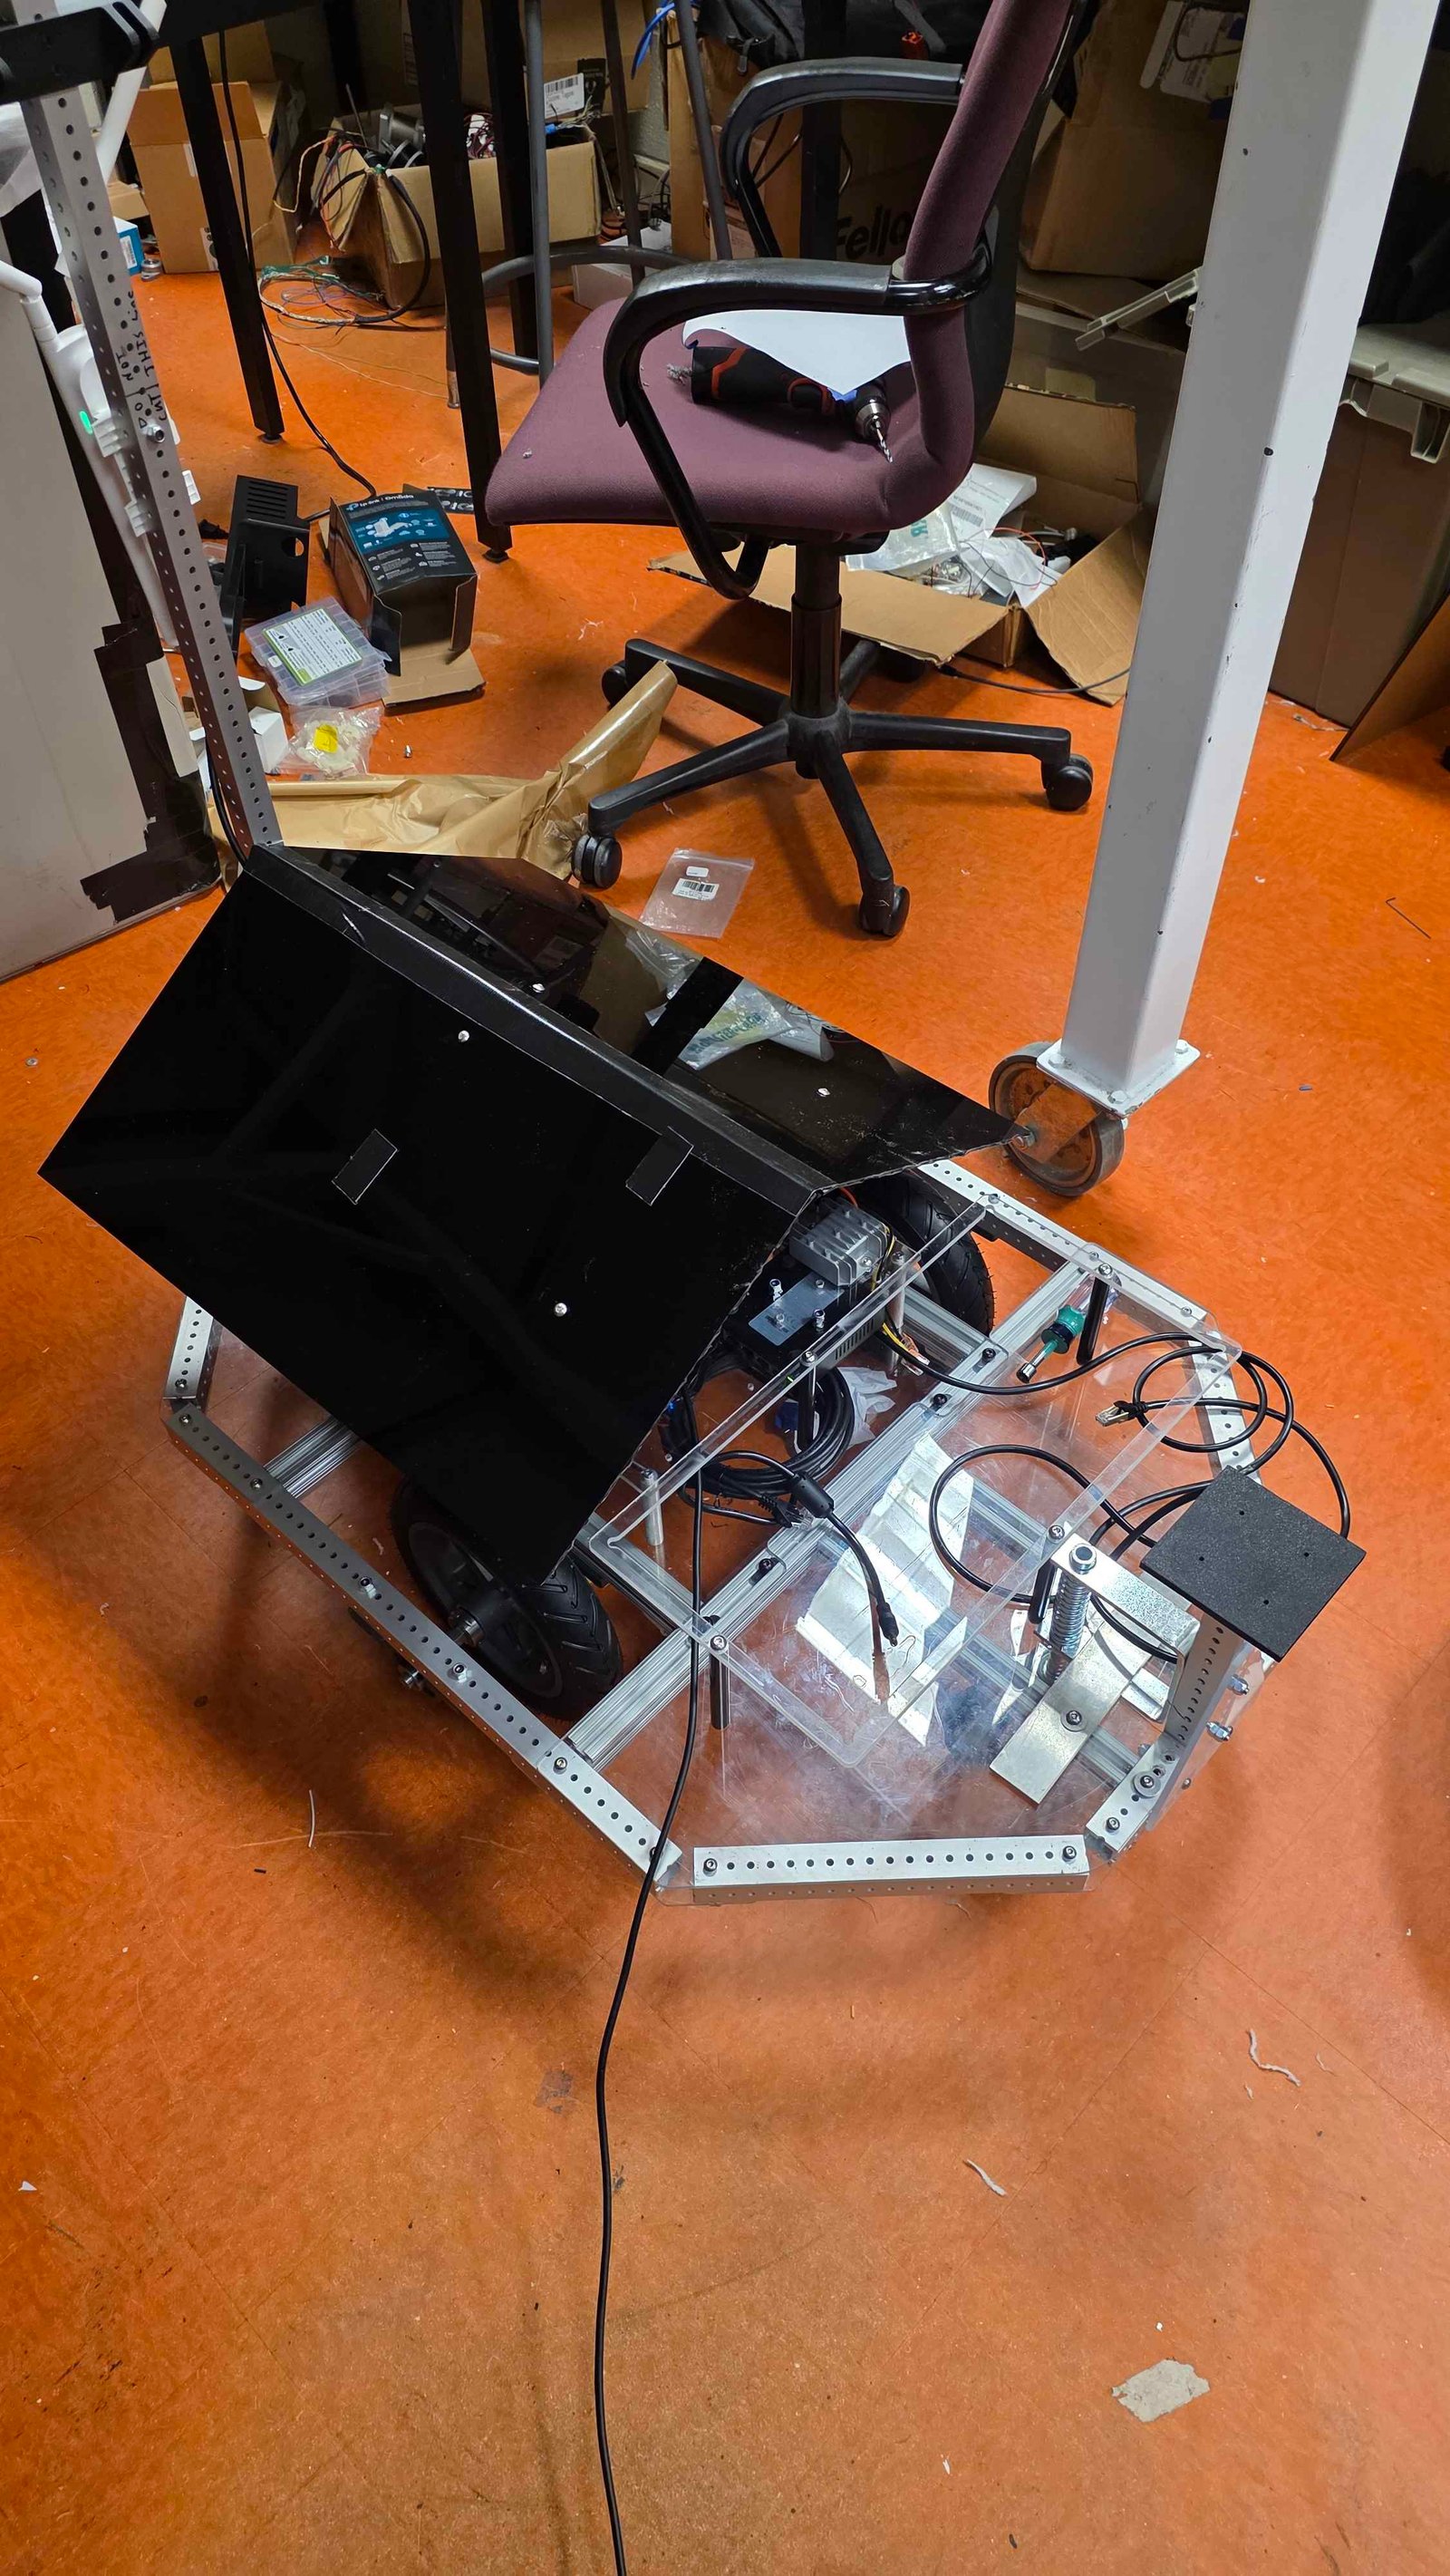
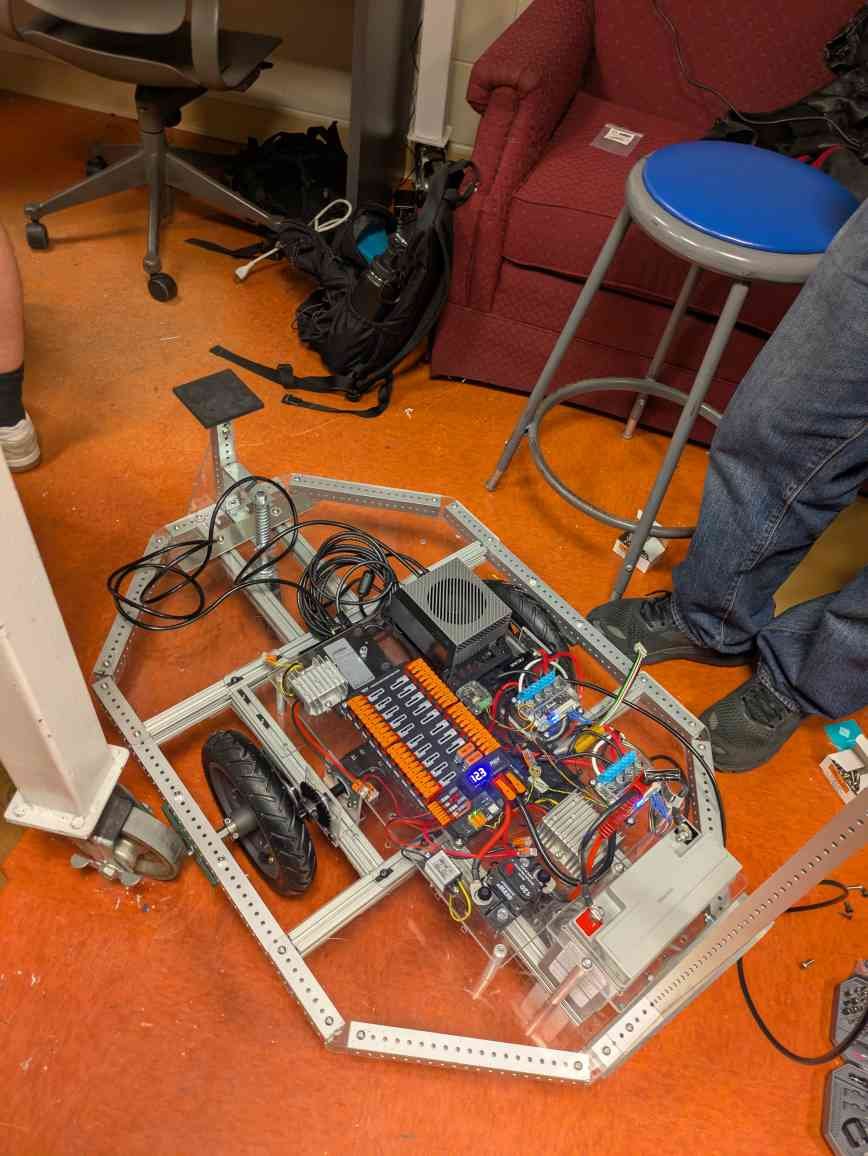
I cut back all four chassis corners to reduce the area swept by the robot as it turned, keeping the rear corners closer to the robot’s center.
Drive system and chassis
Balancing speed and climbing torque
Problem
Keep the vehicle below the 5 mph speed limit while providing enough torque to climb inclines.
Solution
I selected gearbox reductions to increase wheel torque on inclines and keep the motors in an efficient operating range without exceeding the speed limit.